
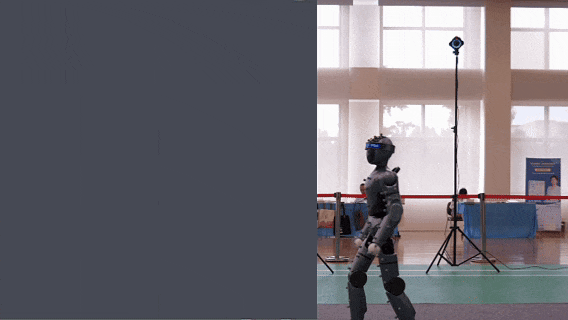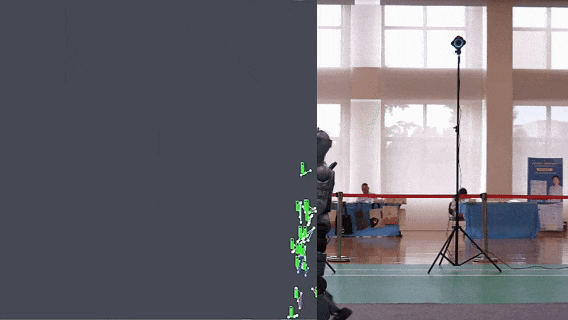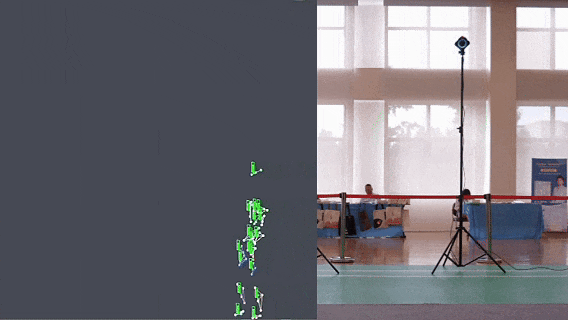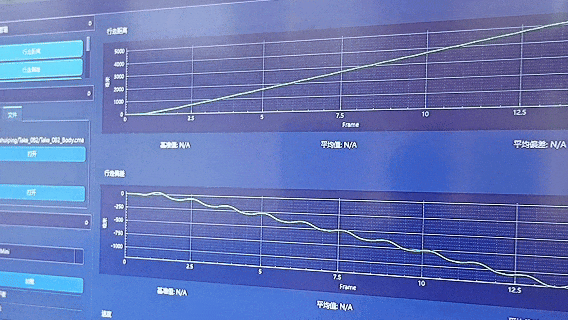
At the 2026 World Robot Conference (WRC), CHINGMU, in collaboration with the Beijing Municipal Culture and Tourism Bureau and the Chinese Academy of Inspection and Quarantine (CAIQ), presented a demonstration of the RoboEval robot motion assessment platform at a sub-venue. Using the approach of "quantifying every movement, verifying every delivery," it completes the final link in the "data-to-action" chain. Built on CHINGMU's high-precision optical motion capture and multi-source data fusion capabilities, RoboEval performs quantitative analysis on robot motion trajectories, 6DoF posture stability, response speed, repeatability, and execution deviation, and can simultaneously integrate data from force plates, video, and other sources.


+86-21-56472866 / 13310099680
1190 Nong METACINE (South Gate), Building 1, CHINGMU, Zhengtai Road,Baoshan District, Shanghai

Hot searches: Motion capture, Optical motion capture, Motion capture system robot, Motion capture, Bionic robot, Motion control, Gait analysis, Rehabilitation training action assessment, Animation production, Virtual idol live streaming, Expression capture, Virtual production, Pre-visualization, Performance capture